Silicon Valley Quantum AI Lab Public Charity Lecture
Embodied Intelligence & Physical AI Lecture 3: Zero-Foundation Hands-On with StackChan & Loop-to-Graph Engineering
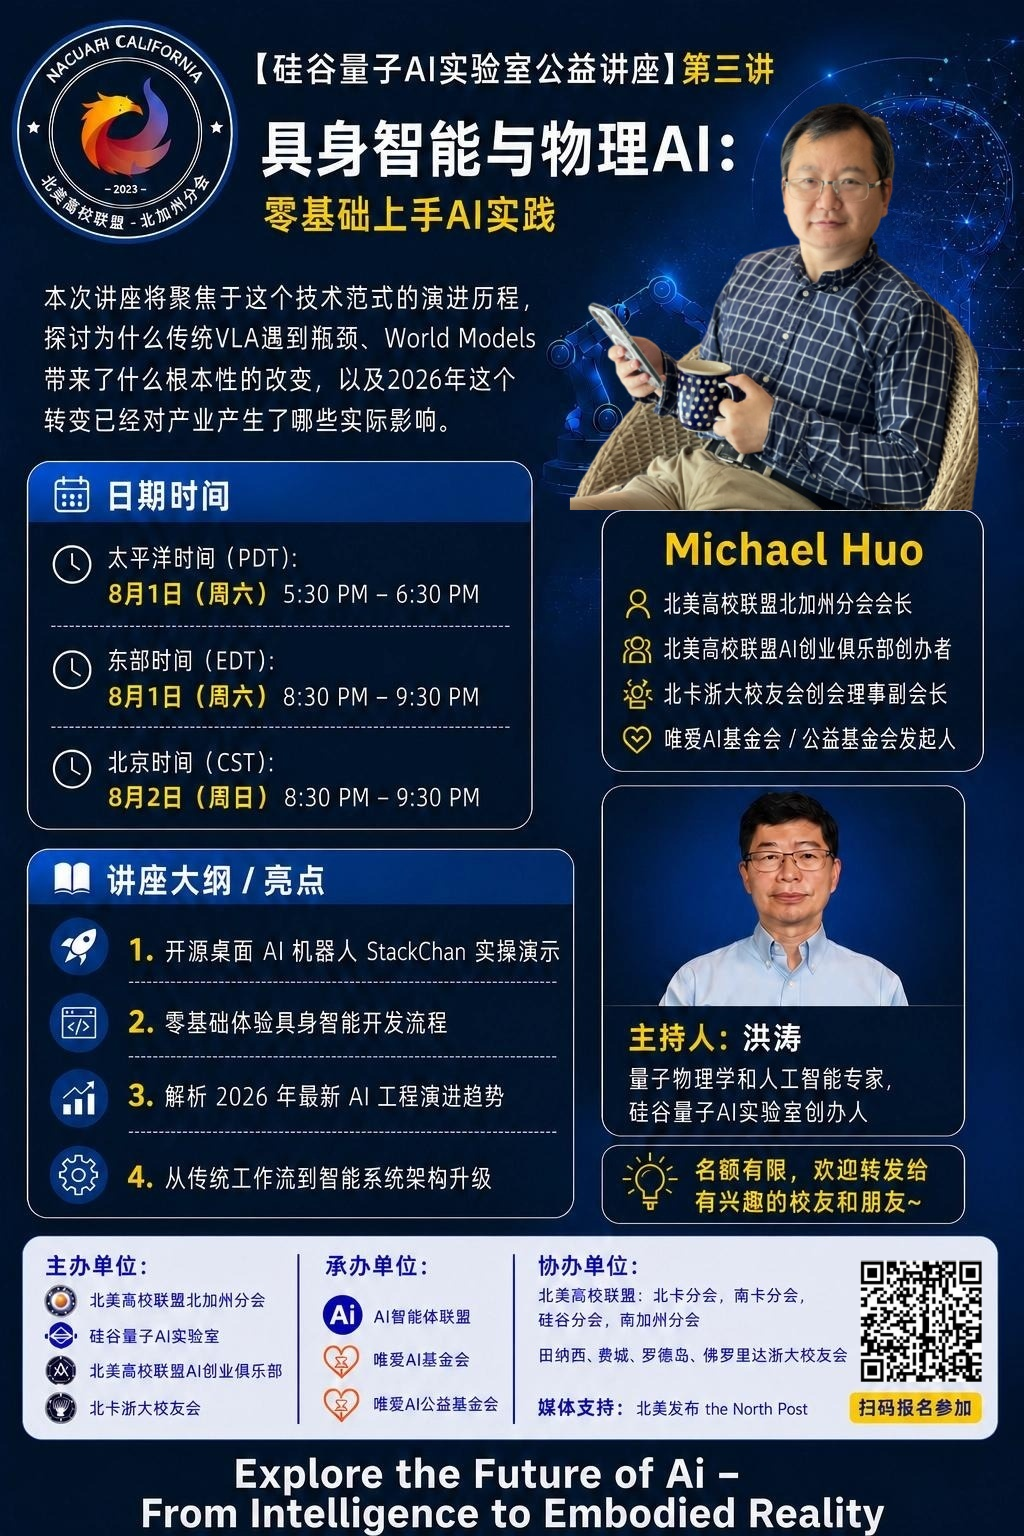
Following Lecture 1 on foundational concepts and Lecture 2 on paradigm shifts from VLA to World Models, Lecture 3 turns directly to hands-on deployment. Using the open-source desktop robot StackChan, attendees learn how to bring Physical AI from theory to working hardware.
Date & Time
- Pacific Daylight Time (PDT): July 29 (Wed) 5:30 PM – 6:30 PM
- Eastern Daylight Time (EDT): July 29 (Wed) 8:30 PM – 9:30 PM
- Beijing Time (CST): July 30 (Thu) 8:30 AM – 9:30 AM
Lecture Outline
- StackChan Architecture & Desktop Robotics Intro
- Component breakdown, M5Stack hardware integration, and sensor telemetry.
- From Simple Loops to State Graphs
- Why traditional polling loops fail in complex physical environments.
- Implementing Graph Engineering for deterministic robotics behavior and graceful error recovery.
- Live Demonstration: End-to-End Voice & Motion Orchestration
- Integrating local SLM/LLM endpoints with physical servo controllers.
- Community Showcase & Open-Source Toolkit Releases
Resources & Downloads
- Presentation Slides & PDF Kits: Download via zju.fyi
- YouTube Recording: Watch Lecture 3 Replay
- Hosts: Silicon Valley Quantum AI Lab, NACUAA AI Venture & Impact Club, ZJUAANC.
- Organizers: AI Agent Alliance, VI AI Foundation, VI AI for Good Foundation.
- Co-organizers: NACUAA Northern California, Silicon Valley, North Carolina, and Washington DC Chapters.
- Media Partner: North Alpha Post